Skip to content

Shanghai, China

Finding signal in the noise.Sibo Zhu 朱思博

Quantitative Trading · Alpha Research · Innoam

PreviouslyRobotics VisionEmbodied ControlAutonomous Racing

About Me

Sibo Zhu / 朱思博

Sibo Zhu 朱思博

I'm Sibo (/ˈsiːboʊ/), an alpha strategy researcher at Innoam Asset Management in Shanghai. I work on quantitative trading, with a focus on equity signals, reproducible research, and the path from model development to live execution. I care about whether an idea remains useful across market regimes and under real operating constraints.

Before finance, I worked on machine perception at MIT and the University of Toronto, led perception for MIT Driverless, and co-founded an AI hardware company as CTO. Across research and product development, the common thread has been turning technical ideas into systems people can use.

Outside work, I snowboard as an AASI Level-II certified instructor, take photographs, and maintain an unusually detailed meal prep system. I welcome conversations about research, engineering, and building products.

Journey

Research, engineering, a startup, and now markets

Jan 2026 — Present

Transitioned into quantitative finance with no prior domain experience and independently developed and deployed two equity trading strategies within six months of joining. Both were formally adopted by the firm for live trading.

Details

Shanghai, China

  • Owned the full research-to-deployment process, from signal research and model development to historical validation and live execution, turning research into trading strategies used by the firm
  • Built point-in-time data checks and reproducible training and execution workflows to detect look-ahead information and verify consistency between research and live operation
  • Developed an automated signal research and screening pipeline, using tests across time periods and paired comparisons to assess incremental value over existing strategies
Oct 2023 — May 2025

Co-founder & Chief Technology Officer

Cyber Partner AI Inc (上海魂伴科技)

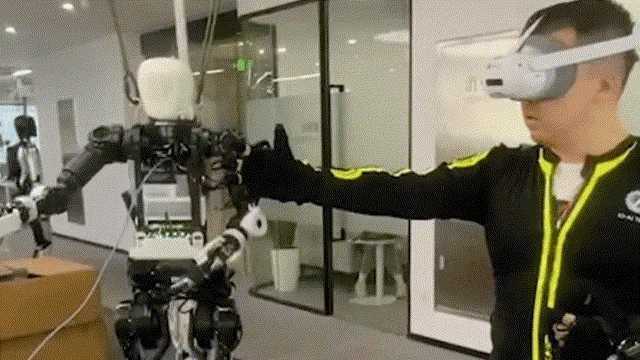
Co-founded Cyber Partner AI and led product and engineering. Took an AI companion device from architecture to mass production, reaching 100,000+ units sold within six months, and delivered a humanoid robot for ongoing visitor engagement at Volcano Engine.

Details

Shanghai, China & Palo Alto, U.S

  • Co-founded the company and led product & engineering: shipped our first AI hardware product to 10,000+ units in month one and 100,000+ within six months
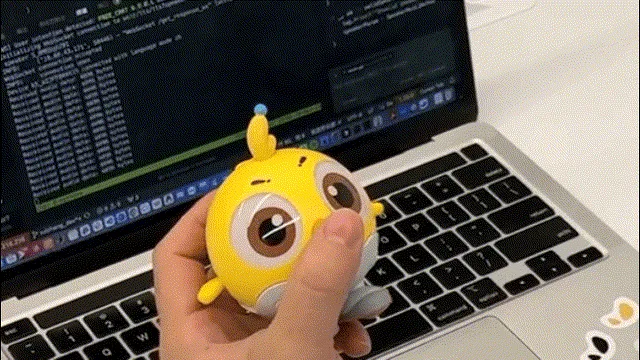
  • Architected the JiFeiFei AI companion with Kaishu Story, combining an ESP32-S3 frontend with cloud-based computation and inference, long-term memory, and a 0.9-second response from the end of user speech to first audio output
  • Owned customer requirements, technical design and overall delivery of a two-meter humanoid robot for ongoing bilingual presentations and brand interaction at Volcano Engine's flagship exhibition hall
  • Built and led cross-functional R&D across embedded firmware, multimodal LLM orchestration, and hardware mass production while securing strategic funding

Sep 2021 — Aug 2023

Ph.D. research on event-camera perception for high-speed autonomous driving under extreme lighting and motion, including sparse Vision Transformers for asynchronous event streams.

Dec 2019 — Aug 2021

Graduate Research Assistant

MIT HAN Lab

Worked with Prof. Song Han on efficient machine perception: self-supervised sensor calibration, end-to-end LiDAR navigation and neural network compression for edge devices.

Details

Cambridge, MA

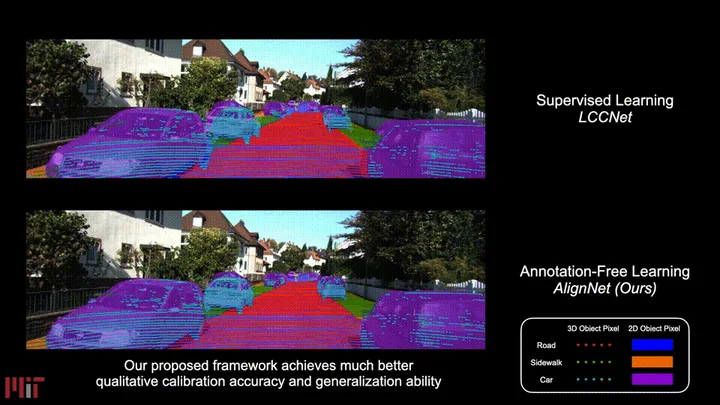
  • Co-developed SemAlign (IROS 2021), a self-supervised sensor calibration framework cutting camera-LiDAR calibration from 3+ hours to under a second (10,000x speedup)
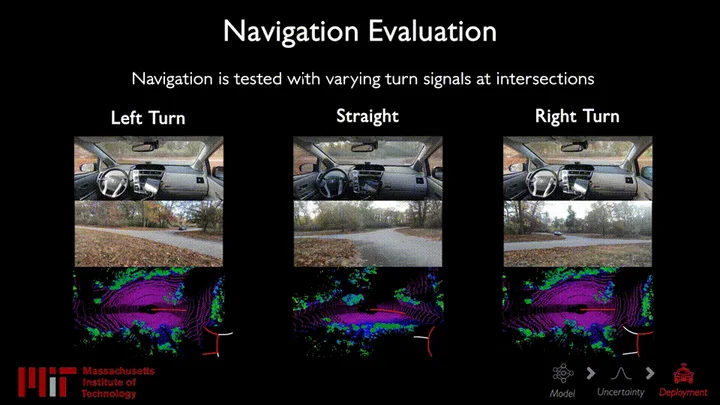
  • Built an efficient end-to-end LiDAR navigation system (ICRA 2021) deployed on a full-scale autonomous vehicle
  • Collaborated with Prof. Song Han on edge neural network compression (PatchNet) adopted across industry

Jan 2019 — Aug 2021

Perception Lead

MIT Driverless

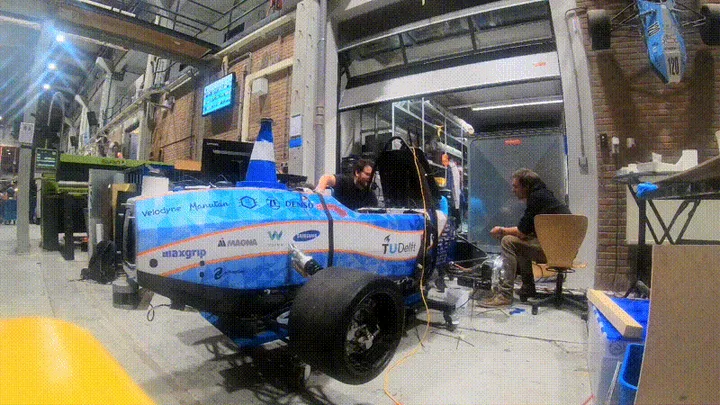
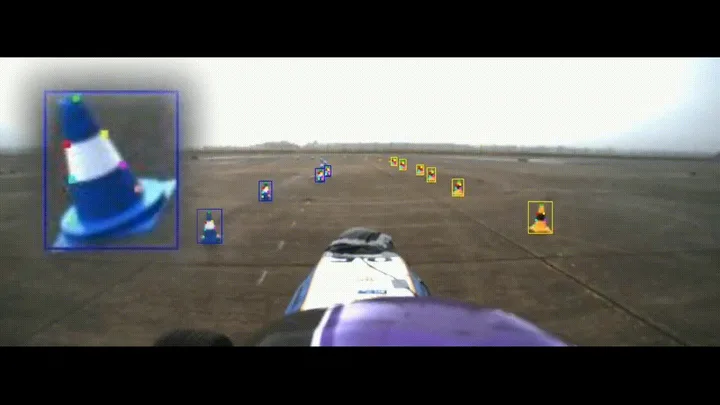
Led a team of more than 20 engineers developing autonomous racing perception, from detection and sensor integration to track testing and open-source infrastructure.

Details

Cambridge, MA

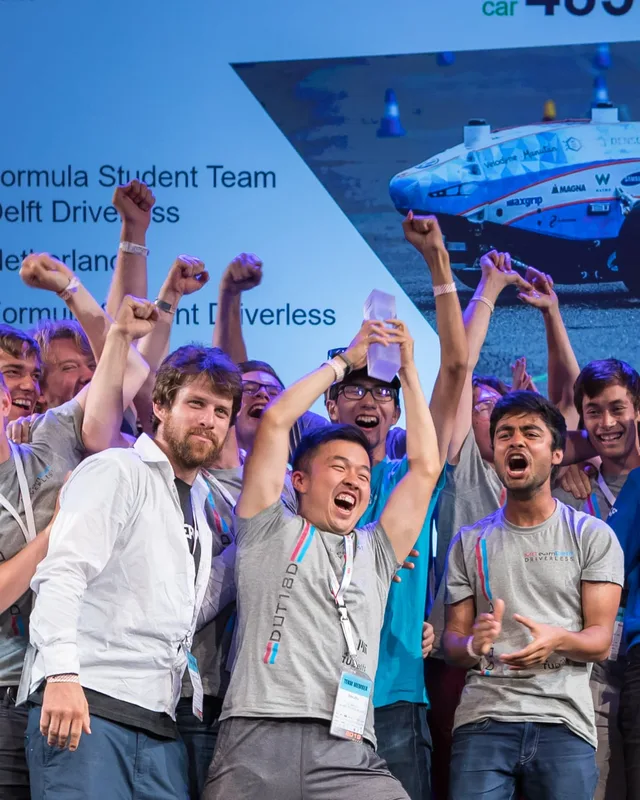
  • Led a 20+ engineer perception team and co-pitched $200K+ in sponsorships from Google, Waymo, and Oracle
  • Pushed perception mAP from 66.97% to 89.35% within a 200ms full-stack latency budget, enabling championship-winning track performance
  • Open-sourced the perception and training infrastructure, adopted by 100+ Formula Student teams globally

Education

  • 2021 - 2023

    University of TorontoPh.D. Studies, Aerospace Science and Engineering (left to co-found Cyber Partner AI)

  • 2018 - 2020

    Brandeis UniversityM.S in Computer Science (AI/ML Specialization)

  • 2014 - 2018

    Boston UniversityB.A in Computer Science + Pure & Applied Mathematics (Double Major)

Selected Work

Research and engineering in AI, robotics and autonomous driving

AI JiFeiFei: AI Companionship with Lasting Memory

Apr 2025Cloud AI / ESP32-S3 / Device–Cloud Architecture

AI JiFeiFei: AI Companionship with Lasting Memory

Built with Kaishu Story, JiFeiFei combines an ESP32-S3 frontend with cloud-based computation and inference for responsive conversation and long-term memory. Response time is 0.9 seconds from the end of user speech to first audio output. Led from product architecture through mass production, it reached 10,000+ units sold in its first month and 100,000+ within six months.

Team: Sibo Zhu (Co-founder & CTO), Cyber Partner AI Team

Explore the project
Bumblebee: A Humanoid Robot for Visitor Engagement

Dec 2024Humanoid Robotics / Conversational AI / Multimodal (Vision/Voice/NLP)

Bumblebee: A Humanoid Robot for Visitor Engagement

A humanoid robot deployed at Volcano Engine’s flagship exhibition hall for ongoing bilingual presentations and brand interaction. I owned the project from customer requirements and technical design through on-site delivery, leading the team in integrating our multimodal conversational AI stack with the Agibot A2 platform.

Team: Sibo Zhu (Co-founder & CTO), Cyber Partner AI Team

Explore the project
SemAlign: Sensor Calibration in Under a Second

Oct 2021Sensor Calibration / Self-supervised / Camera-LiDAR

SemAlign: Sensor Calibration in Under a Second

A co-first-authored camera–LiDAR calibration framework published at IROS 2021. Self-supervised semantic alignment removes the need for manual labels and reduces calibration from more than three hours to under one second.

Collaborators: Zhijian Liu, Haotian Tang, Sibo Zhu, Song Han

Explore the project
MIT Driverless: Autonomous Race Car & Open-Source Ecosystem

Aug 2021Autonomous Racing / System Integration / Team Leadership

MIT Driverless: Autonomous Race Car & Open-Source Ecosystem

Led perception for MIT’s autonomous Formula Student race car, improving detection mAP from 66.97% to 89.35%. The team released its dataset, labeling pipeline and training infrastructure as an open-source foundation used by more than 100 student racing teams.

Collaborators: Sibo Zhu (Perception Lead), MIT Driverless Team

Explore the project
LiDAR End-to-End Navigation: Full-Scale Vehicle Deployment

May 2021End-to-End Learning / Sparse Convolution / LiDAR

LiDAR End-to-End Navigation: Full-Scale Vehicle Deployment

An end-to-end LiDAR navigation framework published at ICRA 2021. Sparse convolution and hardware-aware architecture design connect raw point clouds to steering commands, with deployment on a full-scale autonomous vehicle.

Collaborators: Zhijian Liu, Alexander Amini, Sibo Zhu, Sertac Karaman, Song Han, Daniela Rus

Explore the project
PatchNet: Ultra-Compact CNN for Edge Computing

Mar 2021Model Compression / Temporal Redundancy / 58M FLOPs

PatchNet: Ultra-Compact CNN for Edge Computing

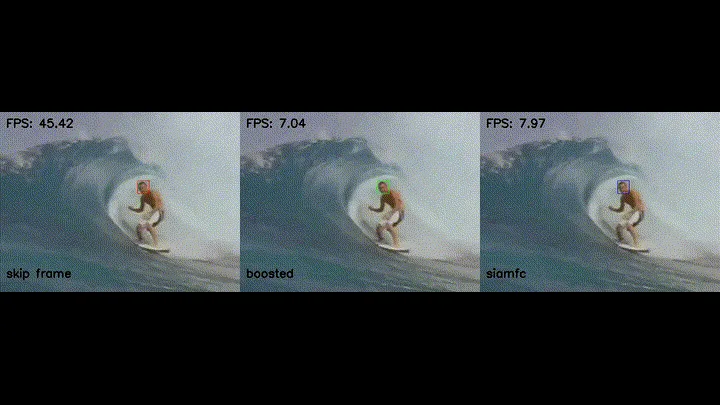
An ultra-compact CNN that reuses temporal information in video to reduce computation to 58M FLOPs. It achieves 5× fewer operations and 4.3× faster inference on edge devices at the same accuracy. The research and implementation are publicly available.

Collaborators: Huizi Mao, Sibo Zhu, Song Han, William J Dally

Explore the project
High-Speed Autonomous Racing: 200ms Full-Stack Vision

Jul 2020Computer Vision / YOLOv3 / 200ms Full-stack Latency

High-Speed Autonomous Racing: 200ms Full-Stack Vision

A vision pipeline for autonomous racing, published at IROS 2020. Optimized YOLOv3 detection, keypoint pose estimation and sub-microsecond stereo synchronization operate within a 200ms full-stack latency budget.

Collaborators: Kieran Strobel, Sibo Zhu, Raphael Chang, Skanda Koppula

Explore the project

Earlier Work

Nov 2020

Faster LiDAR: Real-Time Point Cloud Processing Framework

Attention-based transformer framework for predicting missing LiDAR frames in real-time autonomous driving. 40% throughput improvement with detection accuracy (mAP) unchanged.

Aug 2020

PointPainting: Sensor Fusion Framework Implementation

Implemented nuTonomy's camera-LiDAR fusion model PointPainting, then used it as the evaluation testbed for our 3D point-cloud prediction and sensor calibration research.

Mar 2019

Grad-CAM: CNN Interpretability Framework

A Grad-CAM implementation for visualizing CNN decisions and diagnosing object-detection errors in the autonomous race car’s perception system.

May 2018

Motion Blur Detection: CNN-Based Computer Vision

A CNN for detecting motion blur in high-speed camera systems, achieving 92% accuracy. The open-source implementation has received more than 100 GitHub stars.